
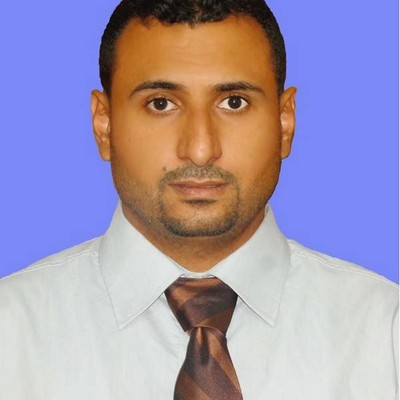
مواقع التدريسيينجامعة الكوفة
علاء عبد الحسين مشكور الظالمي
مدرس مساعد

علاء عبد الحسين مشكور الظالمي

English Version
0بحث منشور
0محاضرة
0اهتمام بحثي

الملف الشخصي

بكالوريوس هندسه كهرباء جامعة بغداد / قسم الهندسة الكهربائية
ماجستير هندسة حاسبات جامعة برليس الماليزية / هندسة تصميم الانظمة المدمجة

الاهتمامات البحثية

2

البحوث المنشورة

5
2022

A tracking control design for linear motor using robust sliding mode learning control

الباحثونMukhalad Al-nasrawi ، Ali Al-Ghanimi Alaa A Aldhalemi
المجلةInternational Journal of Power Electronics and Drive Systems (IJPEDS)
مختصر البحث

Page Header USER Username Password Remember me CITATION ANALYSIS Academia.edu Dimensions Google Scholar Scholar Metrics Scimagojr Scinapse Scilit Scopus QUICK LINKS Call for Papers Focus and Scope Author Guideline Checklist for Preparing Paper Online Paper Submission Publication Fee Abstracting and Indexing Publication Ethics Editorial Boards Contact Us Similarity Report Follow us on Facebook Twitter NOTIFICATIONS View Subscribe JOURNAL CONTENT Search Search Scope All Browse By Issue By Author By Title INFORMATION For Readers For Authors For Librarians HOME ABOUT LOGIN REGISTER SEARCH CURRENT ARCHIVES ANNOUNCEMENTS Home > Vol 13, No 2 > Al-nasrawi A Tracking Control Design for Linear Motor Using Robust Learning Control Mukhalad Al-nasrawi, Ali Al_Ghanimi, Alaa A. Aldhalemi Abstract In this paper, a tracking robust sliding mode learning control (SMLC) is proposed for a linear motor (LM) system. The proposed controller approach, SMLC, can guarantee a zero tracking error in the absence and presence of system uncertainties of the LM system. Unlike other classical sliding mode control (CSMC), the proposed control system is designed without any prior knowledge of the system perturbation which would facilitate control design and simplify its practical applications. To this end, a recursive learning technique is used which simultaneously adapted based on the previous information of the closed loop system stability. The system stability and convergence analysis are rigorously proved in the sense of the Lybenouve criteria. Finally, simulations results are presented to demonstrate the validity and effectiveness of the SMLC over the CSMC in terms of tracking performance and chattering alleviation.

2021

Evaluating the effects of varying model parameter values on the characteristics of a photovoltaic module

الباحثونAmeer Ali Kareem، Alaa Abdalhussain Mashkor Naseem K. Baqer
المجلةspringer/Next Generation of Internet of Things Proceedings of ICNGIoT 2021
مختصر البحث

This paper conducted a review of the most important features and parameters concerned with the modelling of a photovoltaic (PV) cell/module. The primary focus was on the photovoltaic cell, the essential component in the transformation of light into electric current. Furthermore, for the purposes of the present study, it has been depended on previous research to design a simulation model of a photovoltaic cell and module using MATLAB to represent the PV cell and the module. Additionally, based on existing models, the current–voltage and power–voltage characteristics of a photovoltaic module were calculated by varying the values of certain parameters, such as irradiance (G), temperature (T), series resistance (Rs), diode ideality factor (N) and diode reverse saturation current (Ir). The simulation results of the PV module were compared with each other across the range of parameter values.

2020

Design and Implementation of a Remotely Controlled TwoWheel Self-Balancing Robot

الباحثونAlaa A Aldhalemi، Amer A Chlaihawi Ali Al-Ghanimi
المجلةIOP Conference Series: Materials Science and Engineering
مختصر البحث

This research included the design and implementation of a real-time remotely controlled Two-Wheel Self-Balancing Robot (TWSBR). The aim was to build a low cost TWSBR that could be remotely navigated using Bluetooth wireless technology. Experimentally, the TWSBR consists of two parts: the hardware device and the software algorithm. Bluetooth protocols were used to facilitate communication between a smartphone device and a gyroscope sensor. As the dynamic structure of the robot is inherently unstable, self-stabilisation represents a major challenge, and a robust control algorithm was thus required for this task. A Proportional-Integral-Derivative (PID) was employed to achieve this in real-time with the help of an 8-bit microcontroller. The feedback signal was fed to the PID controller through the gyroscope sensor with the aim of maintaining TWSBR stability and balance based on adjusting its longitudinal angle in response to the gyroscope feedback signal. A prototype robot was then built to validate the proposed algorithm.

2020

Second-order terminal sliding mode control based on perturbation estimation for nanopositioning stage

الباحثونAli Al-Ghanimi1 ، Alaa Aldhalemi Jasim Khawwaf
المجلةIET Cyber-systems and Robotics
مختصر البحث

This study proposes a robust second-order terminal sliding mode control with perturbation estimation (2OTSMCPE) strategy with application to trajectory tracking control of the flexure-based nanopositioning system. The proposed controller advantages not only lie on its finite-time convergence but also can provide a high tracking precision with a chattering alleviation which is attend by employing a second-order sliding surface with the switching function. The model of the piezo-driven nanopositioning system is presented first. Second, the sliding variable is designed such as proportional–integral–derivative form to enhance the dynamic response of the control system. Then, a non-singular terminal sliding function (NTSM) is used to achieve the finite-time convergence of the linear sliding variable. Next, a perturbation estimation technique is integrated with the control structure for online estimation of the system uncertainties, thus the prior knowledge of the bounds of system uncertainties are not needed in the proposed control design. Afterwards, the theoretical analysis of the 2OTSMCPE with stability proof is investigated herein. Finally, the system performance with the proposed controller is experimentally verified. The results reveal that the 2OTSMCPE has stronger robustness and also has smoother control signals in comparison with both conventional sliding mode control and the NTSM controller.

2014

Design of an embedded data acquisition system for remote application

الباحثونAlaa A. Aldhalemi، RB Ahmad, M Rahman, ZA Kadhim
المجلةIEEE 2nd International
مختصر البحث

In recent times, various Data Acquisition Systems (DAS) are available in the market. The basic operation of all DAS's are same, only the differences found in terms of hardware architectures, sampling rate, channel supports, costs, user friendly features, etc. This paper proposed an Embedded Data Acquisition System which appealing features are: variable channel supports (2/4/8/32/64), notification sends to admin using Short Message Service (SMS), and web monitoring system which trend to use our system in remote area and named as Embedded Remote Data Acquisition System (ERDAS). In this research, the development phase consists, a Single Board Computer (SBC, TS-7800) as a processing unit, GNU/Linux based Embedded Debian 7 Operating System (OS) as an application development platform and customized kernel module to support 3G modem for notification send/receive to/from the remote area. Results show the developed GUI and accuracy based on CPU and memory usage. We found that the variation of CPU load is 2% to 3% and the memory usage is around 2MB, which conclude that the technically compact designed ERDAS modules are fitting to execute on the low-end embedded hardware and OS.

المحاضرات

18

Algorithm and Flowchart-3

حاسبات

Computer keyboard and shortcut keys

حاسبات

Windows Operating System

حاسبات

Basic of MS-DOS commands-1

حاسبات

Basic of MS-DOS commands-2

حاسبات

Basic of MS-DOS commands-3

حاسبات

Introduction to Batch Files-1

حاسبات

Introduction to Batch Files-2

حاسبات

Introduction to Batch Files-3

حاسبات

Microsoft Office Word

حاسبات

Microsoft Office Excel

حاسبات

Microsoft Office PowerPoint

حاسبات

Introduction to Internet

حاسبات

matrix

C programming

Function

C programming

array

C programming

pointer

C programming

ALGORITHM AND FLOWCHART

C programming

عرض التفاصيل